
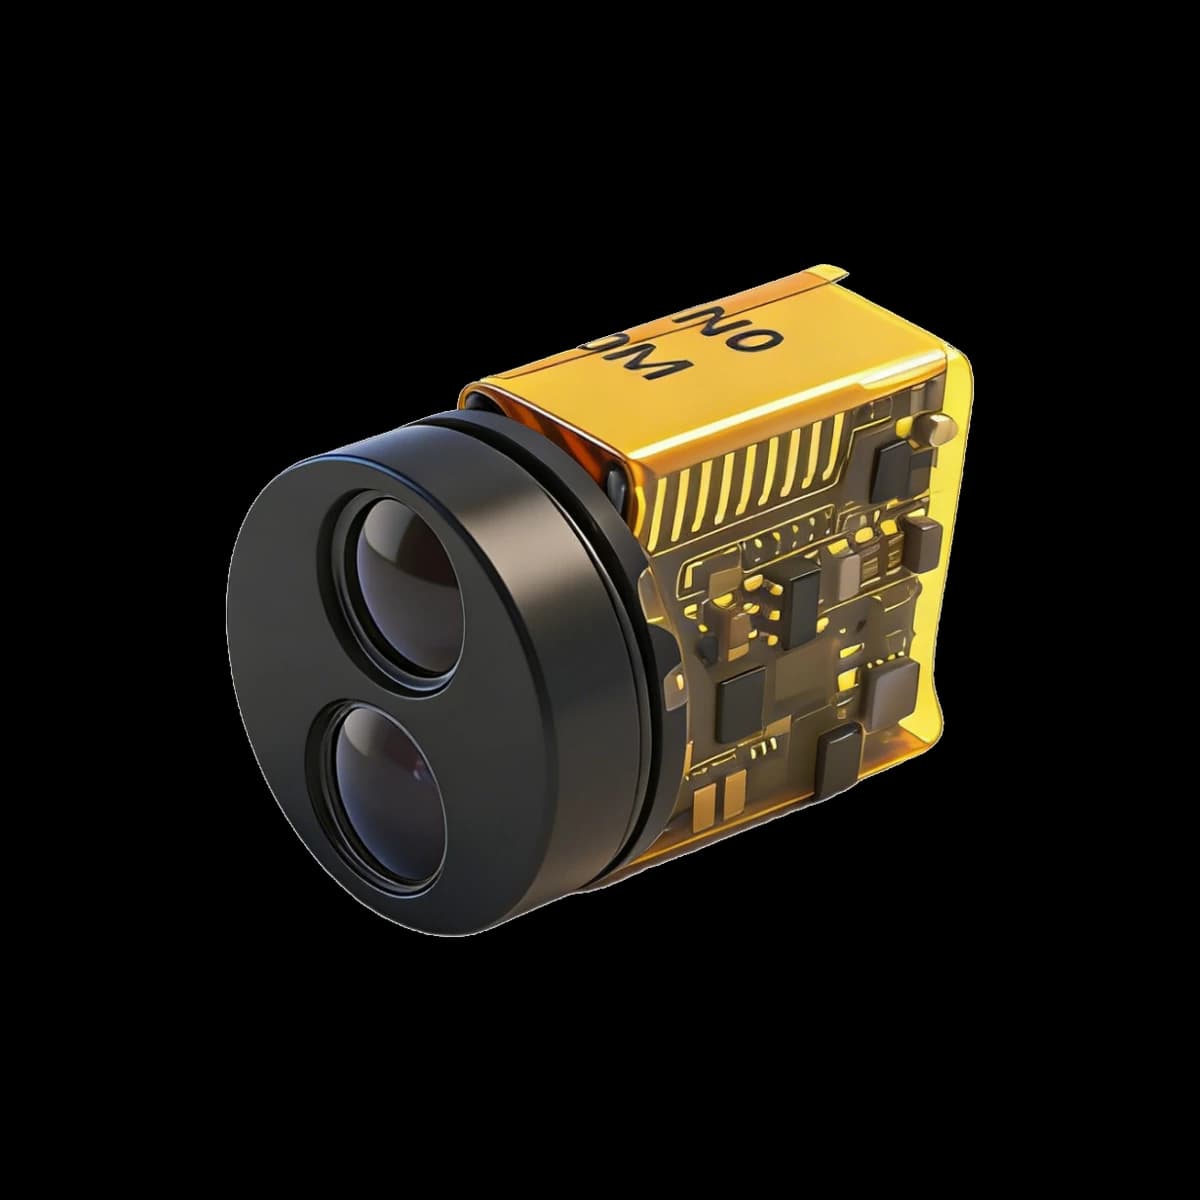
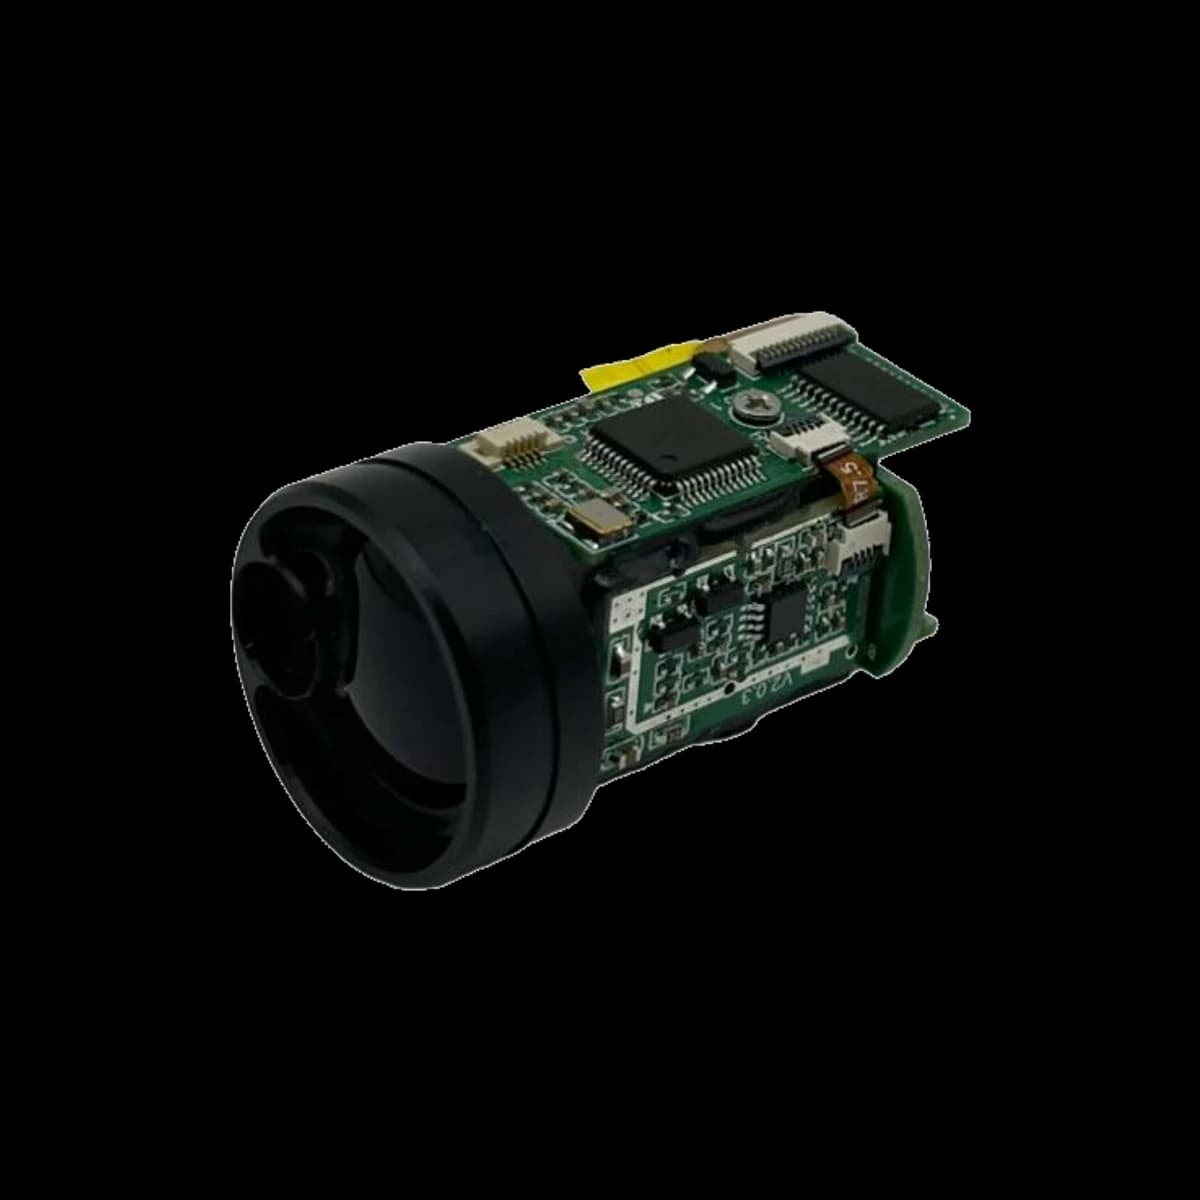
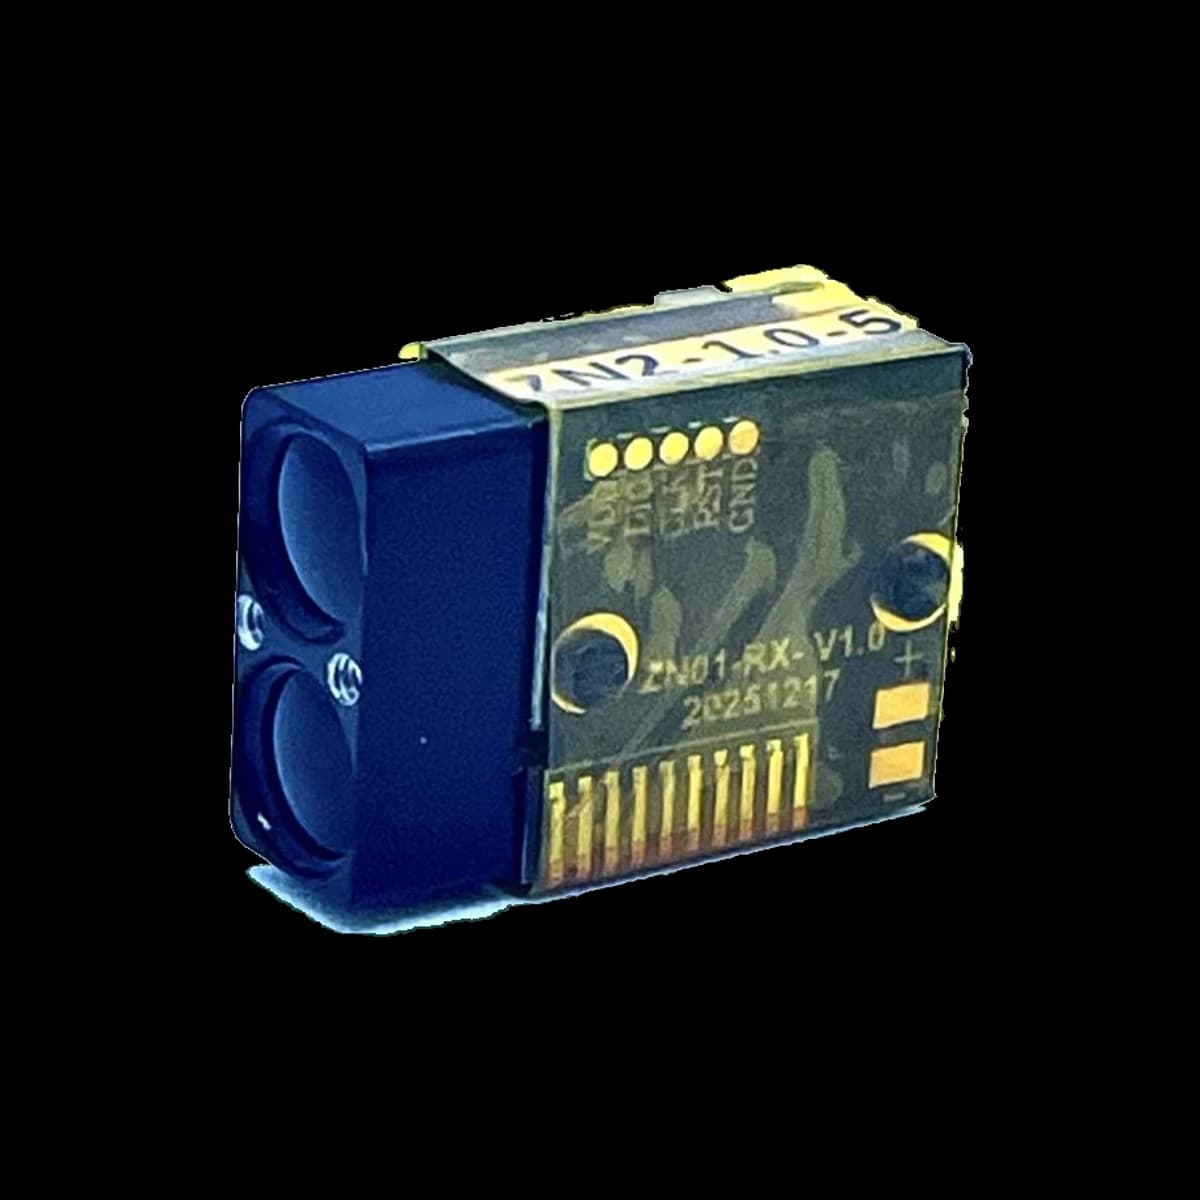
SPD1200N0 OEM Ranging and Integration
SPD1200N0 is a compact 905 nm laser ranging module with a 0.2–1200 m source-table ranging distance. The source documents UART-TTL communication and a circular housing specific to this model. The specifications, drawings and electrical definitions below remain bound to this model. The technical literature section explains general principles without asserting an undocumented receiver architecture.
Detailed SPD1200N0 Specifications
Read the values together with their source conditions. Literature and related-model data do not replace these ratings.
| Parameter | Value | Source condition |
|---|---|---|
| Laser wavelength | 905 nm ±5 nm | SPD1200N0 controlled source technical table |
| Beam divergence | <4.5 mrad | SPD1200N0 controlled source technical table |
| Optical material | Aspheric lens | SPD1200N0 controlled source technical table |
| Receiver aperture | Diameter 6.5 mm | SPD1200N0 controlled source technical table |
| Ranging distance | 0.2–1200 m; maximum 1500 m at night | SPD1200N0 controlled source technical table; strong sunlight or low visibility may reduce range |
| Ranging accuracy | ±0.3 m (D ≤100 m); ±0.3 m + D × 0.7‰ (100 m < D <1200 m) | SPD1200N0 controlled source technical table |
| Measurement frequency | 2–15 Hz or 4–15 Hz, adaptive | SPD1200N0 controlled source technical table; both alternatives appear in the same formal source row |
| Valid measurement rate | ≥98% | SPD1200N0 controlled source technical table |
| False-alarm rate | ≤1% | SPD1200N0 controlled source technical table |
| Communication interface | UART-TTL (customizable) | SPD1200N0 controlled source technical table |
| Baud rate | 115200 bps (default) | SPD1200N0 controlled source technical table |
| Supply voltage | 3.3–5 V | SPD1200N0 controlled source technical table |
| Startup time | ≤200 ms | SPD1200N0 controlled source technical table |
| Operating power | Average ≈0.45 W; maximum ≤0.75 W | SPD1200N0 controlled source technical table |
| Operating temperature | -20°C to +60°C | SPD1200N0 controlled source technical table |
| Storage temperature | -30°C to +70°C | SPD1200N0 controlled source technical table |
| Protection rating | IP67 inside lens chamber | Source-stated classification or rating; not independently certified by this page |
| Laser safety class | IEC Class I | Source-stated classification or rating; not independently certified by this page |
| Dimensions | Diameter 15.7 × 21.3 mm (round, with sealing groove) | SPD1200N0 controlled source technical table |
| Weight | ≈5 g | SPD1200N0 controlled source technical table |
| Shock | 1000 g/ms (10 times/s along optical axis) | SPD1200N0 controlled source technical table; source test wording retained |
| Vibration | 5–50–5 Hz, 1 octave/min, 2.5 g | SPD1200N0 controlled source technical table |
| Reliability | MTBF ≥1500 h | SPD1200N0 controlled source technical table |
Functional Description
The source lists baud-rate modification as a serial-interface function.
Single ranging measures the target once. For a low-reflectivity target, the source says the module repeats measurements until stable distance data is obtained and reports it through the serial interface.
Repeated-ranging mode performs continuous distance measurement. The functional section states a typical configurable 2 Hz refresh rate and a maximum of 15 Hz; the formal frequency row separately retains both 2–15 Hz and 4–15 Hz alternatives.
Electrical Interface Definition
| Pin | Signal | Function |
|---|---|---|
| 1 | GND | Power ground |
| 2 | VCC | Positive supply |
| 3 | IO (reserved) | Reserved for expansion |
| 4 | TXD | Signal output, rangefinder module to host |
| 5 | RXD | Signal input, host to rangefinder module |
| 6 | SW-SHOT | Function enable; no public default polarity is stated |
Check the numbered connector view before wiring. Supply voltage and UART input tolerance are different electrical limits.
Mechanical Dimension Drawing and Electrical Interface Diagram
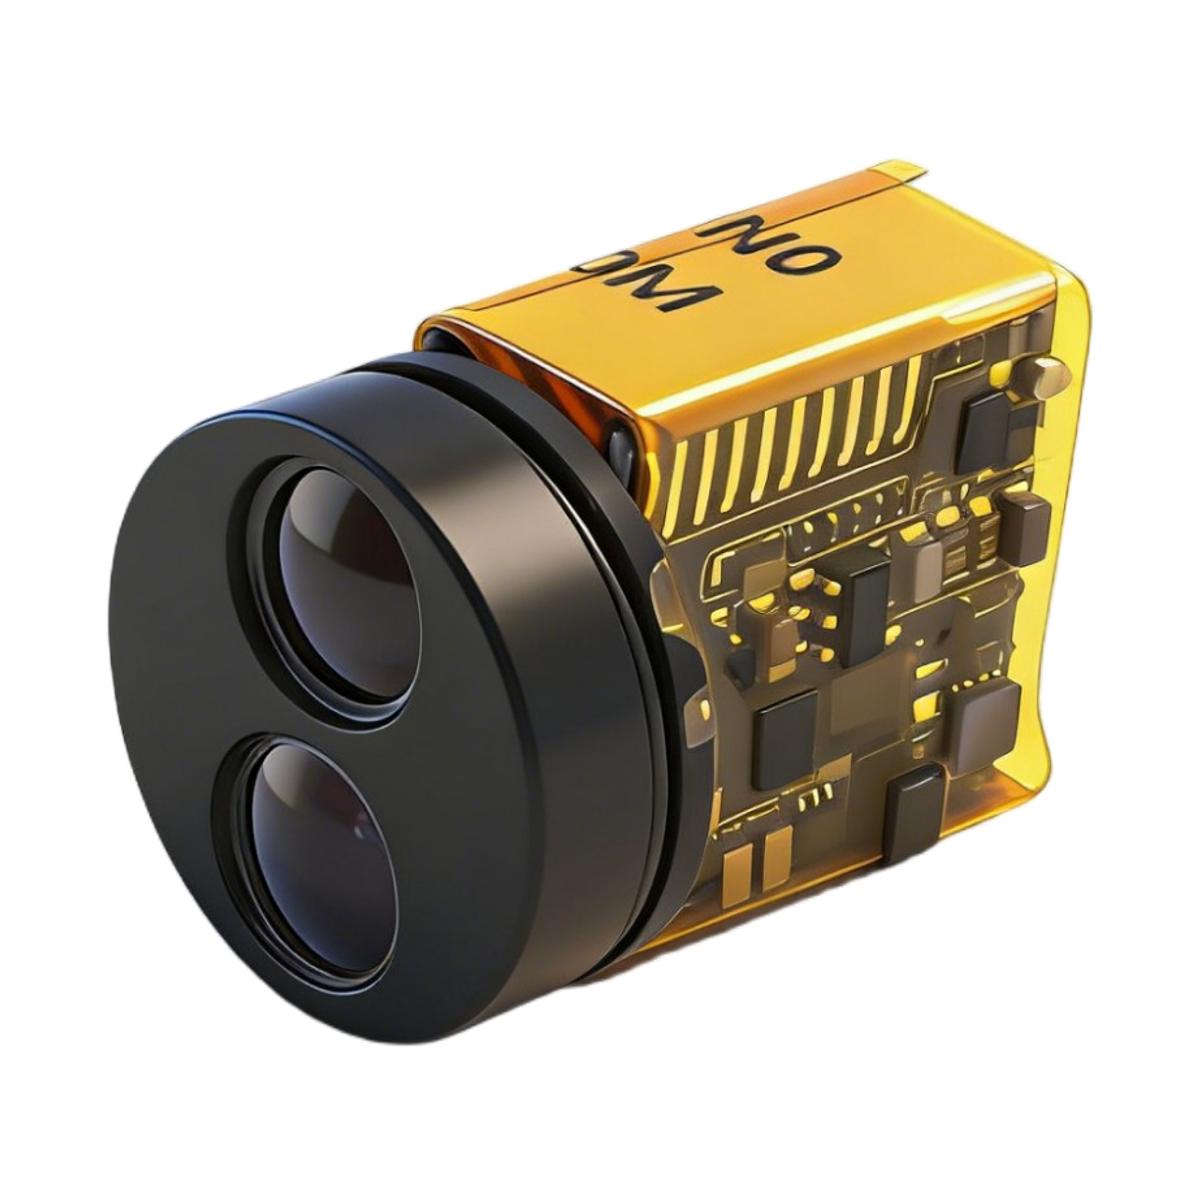
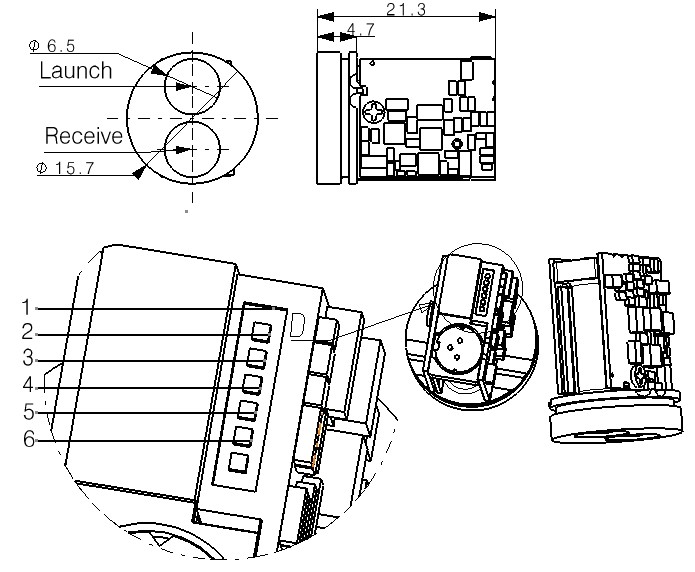
The model PDF controls product claims. Independent literature explains general principles and does not qualify this module.
Pulsed Laser and Single-Photon Receiver Technology
This is technology background for evaluating SPD1200N0, not a claim that its source documents specify a SPAD, TDC, histogram engine or particular chip. Model-specific architecture requires confirmation.
Transmit pulse and timing reference
Target reflection and receive optics
Photon detection and event timing
Return estimation and host output
Pulsed Emission and the Timing Reference
Direct time-of-flight ranging measures the delay between a transmitted optical pulse and its return. In the usual propagation approximation, R = cΔt / 2: R is the one-way range, Δt is the round-trip travel time, and c is the propagation speed. Division by two accounts for the outward and return paths. Pulse shape, timing uncertainty, receiver response and target geometry influence the result. [R1]
Avalanche Detection and Recovery
A SPAD operates above avalanche breakdown so that an absorbed photon can initiate a detectable avalanche. Quenching stops that avalanche, followed by recovery. Single-photon sensitivity does not mean every incident photon is detected. Dark counts, afterpulsing and, in detector arrays, neighbor-induced optical crosstalk can also contribute events. [R2]
From Event Timing to a Histogram
Published direct-ToF designs encode arrival time with a time-to-digital converter and accumulate events in histogram bins. A concentration of events can indicate a return delay. Hutchings and colleagues demonstrate this in a research imager; the example does not identify ERDI's internal circuit or algorithm. [R3]
Separating Signal from Ambient Background
Detections do not arrive with labels identifying their origin. Under the statistical model studied by Rapp and Goyal, pulse-related returns cluster in time while steady background contributes broadly distributed events. Separating a return from ambient light is therefore a statistical task, not simply counting every photon as useful signal. [R4]
Dead Time and Pile Up
During recovery, a detector cannot register another photon. In first-event acquisition, early detections can prevent later arrivals from being recorded. At high flux this selection can distort the distribution, a phenomenon called pile-up. More incident light is not automatically better. The effect depends on the acquisition architecture and operating conditions. [R5]
Detector Crosstalk and Window Reflections
Detector-array crosstalk occurs when an avalanche in one detector causes an unwanted event in another. Optical assembly crosstalk is different: emitted light can reflect inside a protective window and reach the receiver without the intended target round trip. ST documents resulting false or shortened readings in its own sensor. Its distances, calibration procedures and immunity claims must not be transferred to ERDI modules. [R2] [R6]
Evaluate the Complete Installation
Target and range
Match target size, reflectivity, angle and background light to the model's source-stated measurement conditions.
Power and interface
Verify startup current, signal voltage, common ground, connector orientation and firmware-matched serial packets.
Mechanical envelope
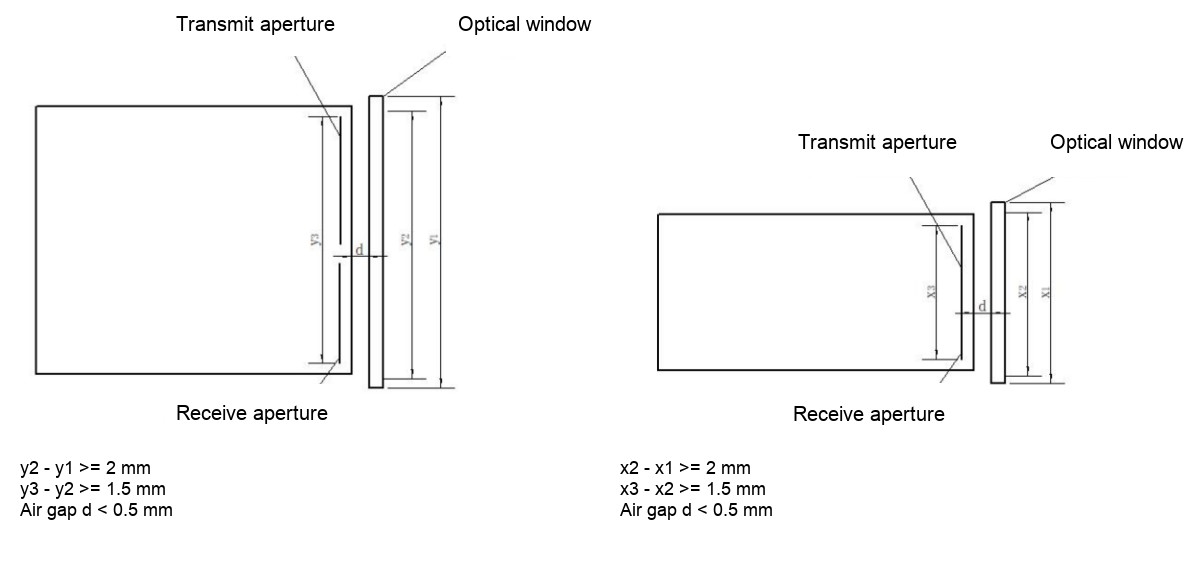
Release mounting and optical apertures against the controlled drawing and tolerances, not a rendered image alone.
Qualification and safety
Test the assembled window and enclosure. Reassess accessible emission, operating modes and labeling in the finished equipment.
Civilian Integration Applications
- Auxiliary ranging in handheld night-vision devices, thermal imagers, telescopes and laser illuminators
- Civilian monitoring, aviation, communications, railway, law-enforcement, smart-water-conservancy and outdoor-sports ranging scenarios
Application examples are evaluation contexts, not proof of fitness without system testing.
Configuration, Window and Safety Review
Confirm the laser operating modes, enclosure, final protective window, firmware protocol, target and installation with ERDI. A related model's indicator or inertial function must not be assumed for SPD1200N0.
Frequently Asked Questions
Can SPD1200N3 or SPD1200ZG specifications replace the SPD1200N0 specification?
No. The SPD1200N0 tables and drawings on this page retain their model-specific source. A common family name, appearance or literature reference does not establish matching range, receiver architecture, indication, inertial functions or firmware. Request the configuration-matched manual before design release.
Does single-photon reception mean one photon always gives a valid distance?
No. A detection may originate from the target, background light or detector noise. A reliable estimate needs sufficient evidence to distinguish the return. Photon-efficient research does not establish a universal one-photon measurement guarantee. [R4]
What is the role of a TDC and a histogram?
A TDC digitizes arrival time; a histogram counts events in time intervals. They can reveal repeated return timing. This explains a general approach, not this module's internal architecture. [R3]
Can strong sunlight affect a single-photon receiver?
Yes. Strong background illumination can increase unrelated detections and distort acquisition at high photon flux. Single-photon sensitivity is not sunlight immunity. Evaluate the complete installation under representative lighting. [R5]
Does a finer time bin equal better specified ranging accuracy?
No. Final accuracy includes more than digitization, and an estimator can use neighboring-bin information. Compare model-specific accuracy and test conditions, not an isolated timing number. [R3]
Are detector dead time and measurement update rate the same?
No. Dead time is an interval of detector or timing-circuit unavailability. Product update rate describes how often completed measurements are reported. Do not infer one from the other without the acquisition specification. [R2]
Why should the final protective window be tested?
Internal reflections can send transmitter light toward the receiver and create unwanted near-range signals. Check the assembled window rather than assuming a bare-module result will remain unchanged. Use an ERDI-approved procedure for the ordered configuration, not another manufacturer's calibration recipe. [R6]
Is the quoted maximum range guaranteed for every target?
No. Target reflectivity, incidence angle, beam footprint and background illumination affect practical ranging. Compare the intended target and installation with the conditions accompanying the model's stated range. [R1]
Does this technical explanation establish the same architecture for every N-series model?
No. Generic literature is not a model-specific bill of materials. Do not infer the internal receiver, timing circuit, histogram processing, indication function or firmware compatibility of SPD1200N0, SPD1200N2 or SPD1200N4 from a related model. Use the current specification and obtain configuration-specific confirmation where needed.
References and Evidence Boundaries
- [R1] Performance Analysis of Next-Generation LADAR for Manufacturing, Construction, and Mobility
Stone et al., NISTIR 7117 (2004), DOI 10.6028/NIST.IR.7117. Sections 2.1–2.1.1 support round-trip ranging and practical influences, not an ERDI receiver design or rating.
- [R2] Statistical Modelling of SPADs for Time-of-Flight LiDAR
Incoronato, Locatelli and Zappa, Sensors 21(13), 4481 (2021). Sections 2–3 cover avalanche operation, recovery, afterpulsing, array crosstalk and acquisition limitations. They do not identify ERDI's implementation.
- [R3] A Reconfigurable 3-D-Stacked SPAD Imager With In-Pixel Histogramming for Flash LIDAR or High-Speed Time-of-Flight Imaging
Hutchings et al., IEEE JSSC 54(11), 2947–2956 (2019), DOI 10.1109/JSSC.2019.2939083. Sections II–III demonstrate timing, histogramming and range estimation. The research imager's architecture and performance are not ERDI specifications.
- [R4] A Few Photons Among Many: Unmixing Signal and Noise for Photon-Efficient Active Imaging
Rapp and Goyal, IEEE TCI 3(3), 445–459 (2017), DOI 10.1109/TCI.2017.2706028. Sections II–III explain statistical signal/background separation. Neither the algorithm nor experimental results are claimed for ERDI.
- [R5] Photon-Flooded Single-Photon 3D Cameras
Gupta, Ingle, Velten and Gupta, author manuscript v2 (2019), repository DOI 10.48550/arXiv.1903.08347. Sections 1–3 explain first-event pile-up and high-flux tradeoffs. First-event acquisition is architecture-specific; the prototype is not an ERDI test.
- [R6] A guide for using the VL53L8CX, low-power, high-performance Time-of-Flight multizone ranging sensor
STMicroelectronics UM3109, Rev 12 (August 2025), Calibration flow. Manufacturer evidence of protective-window reflections and unwanted range signals in another manufacturer's 940 nm system. Its calibration instructions, dimensions and immunity claims do not apply to ERDI modules.
Independent literature supports the explanations, not module qualification. Use the source-linked model manual and ERDI configuration confirmation for procurement and design release.