
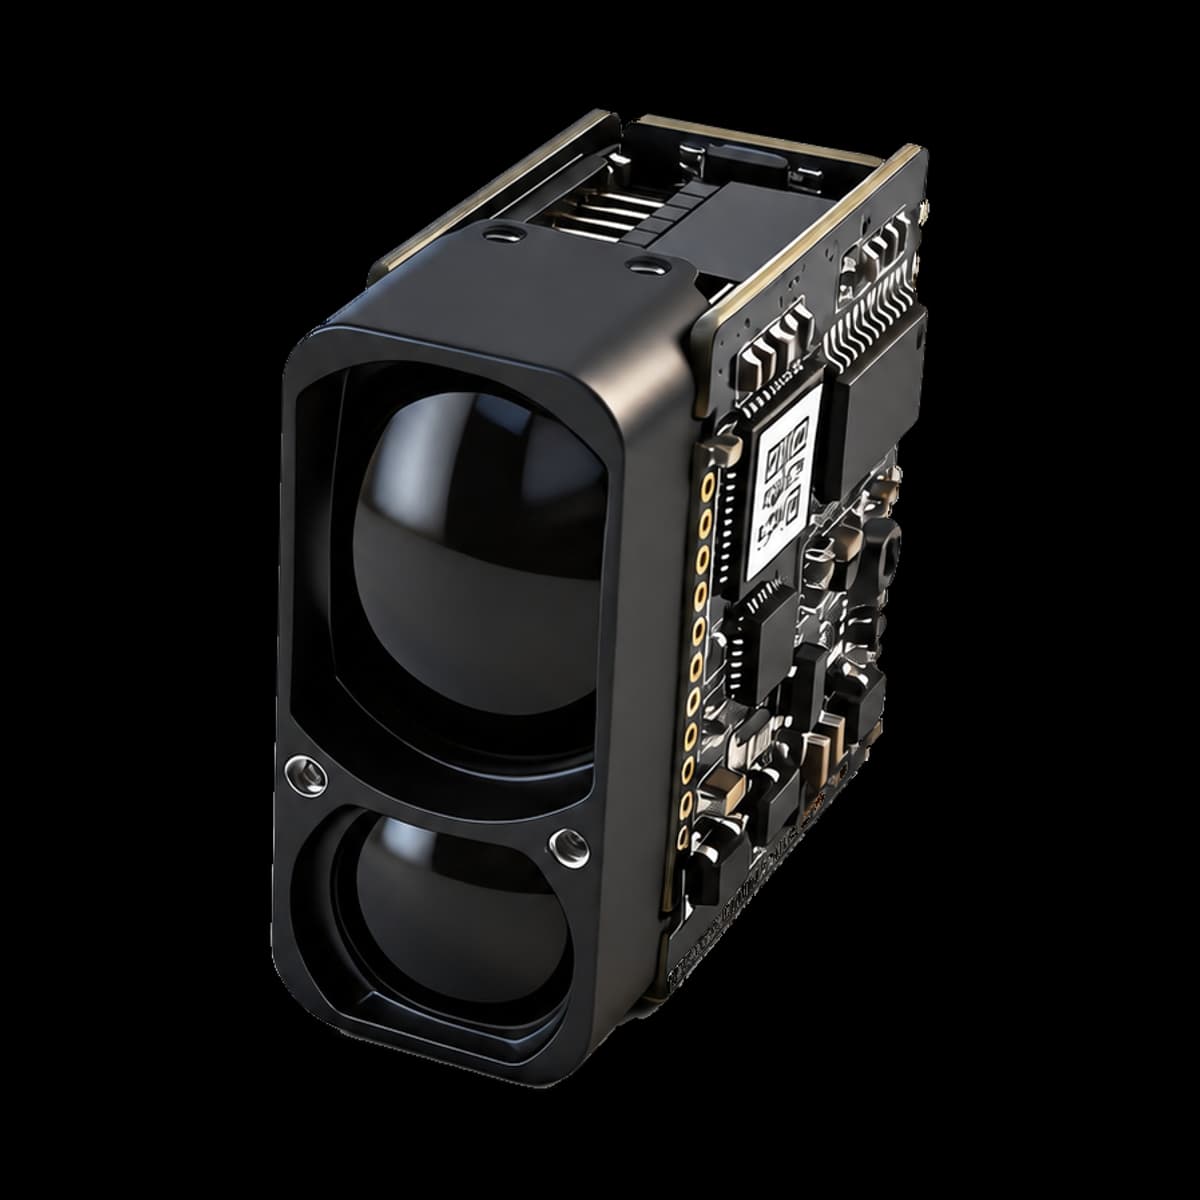
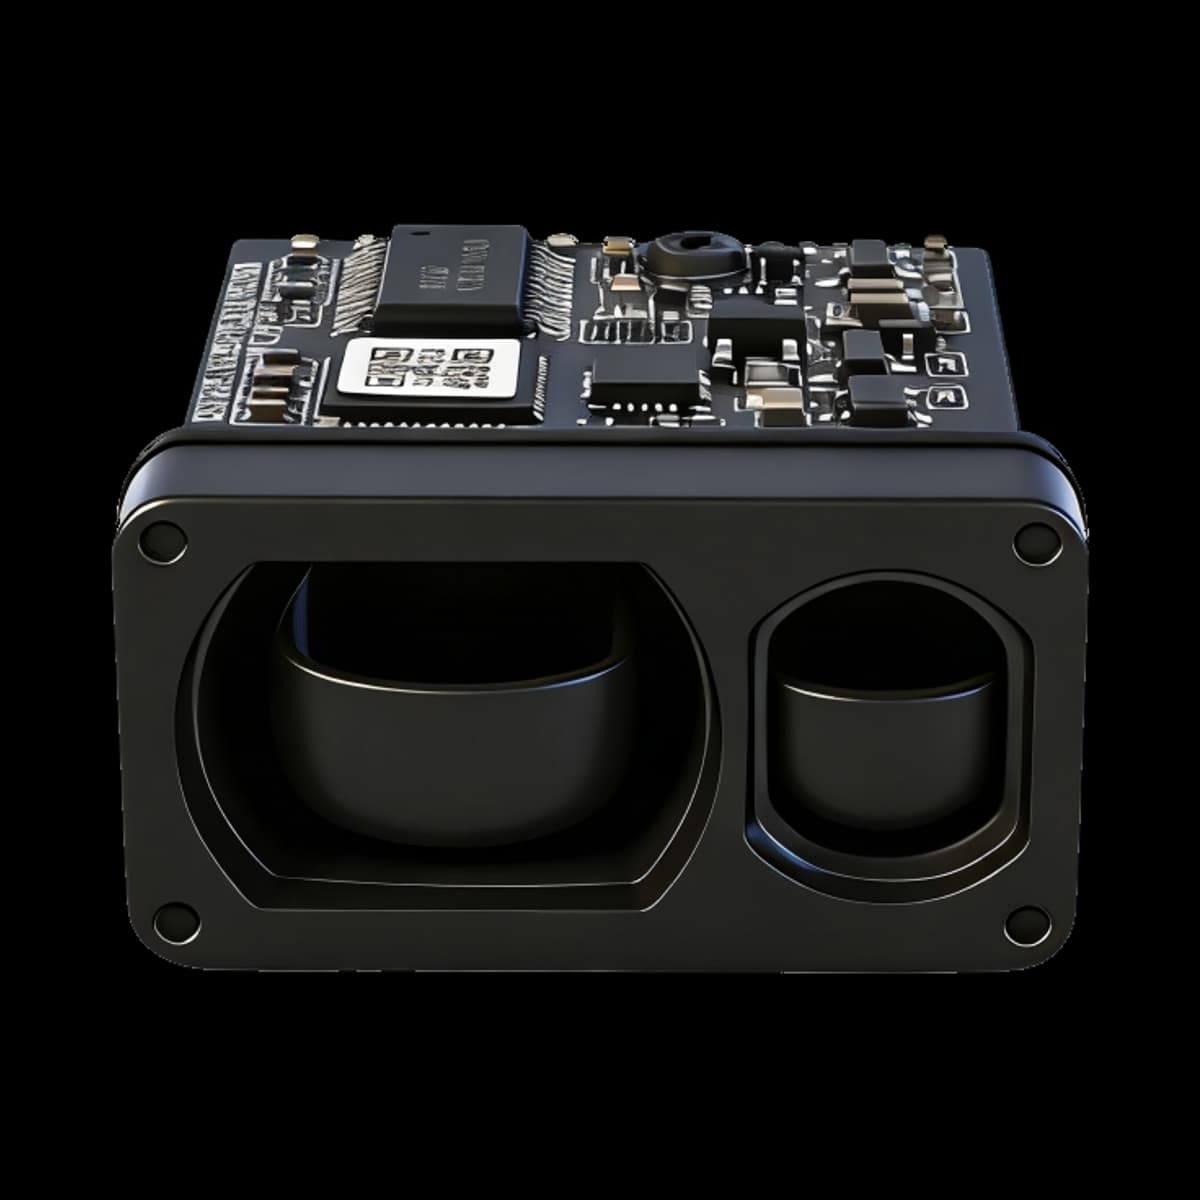
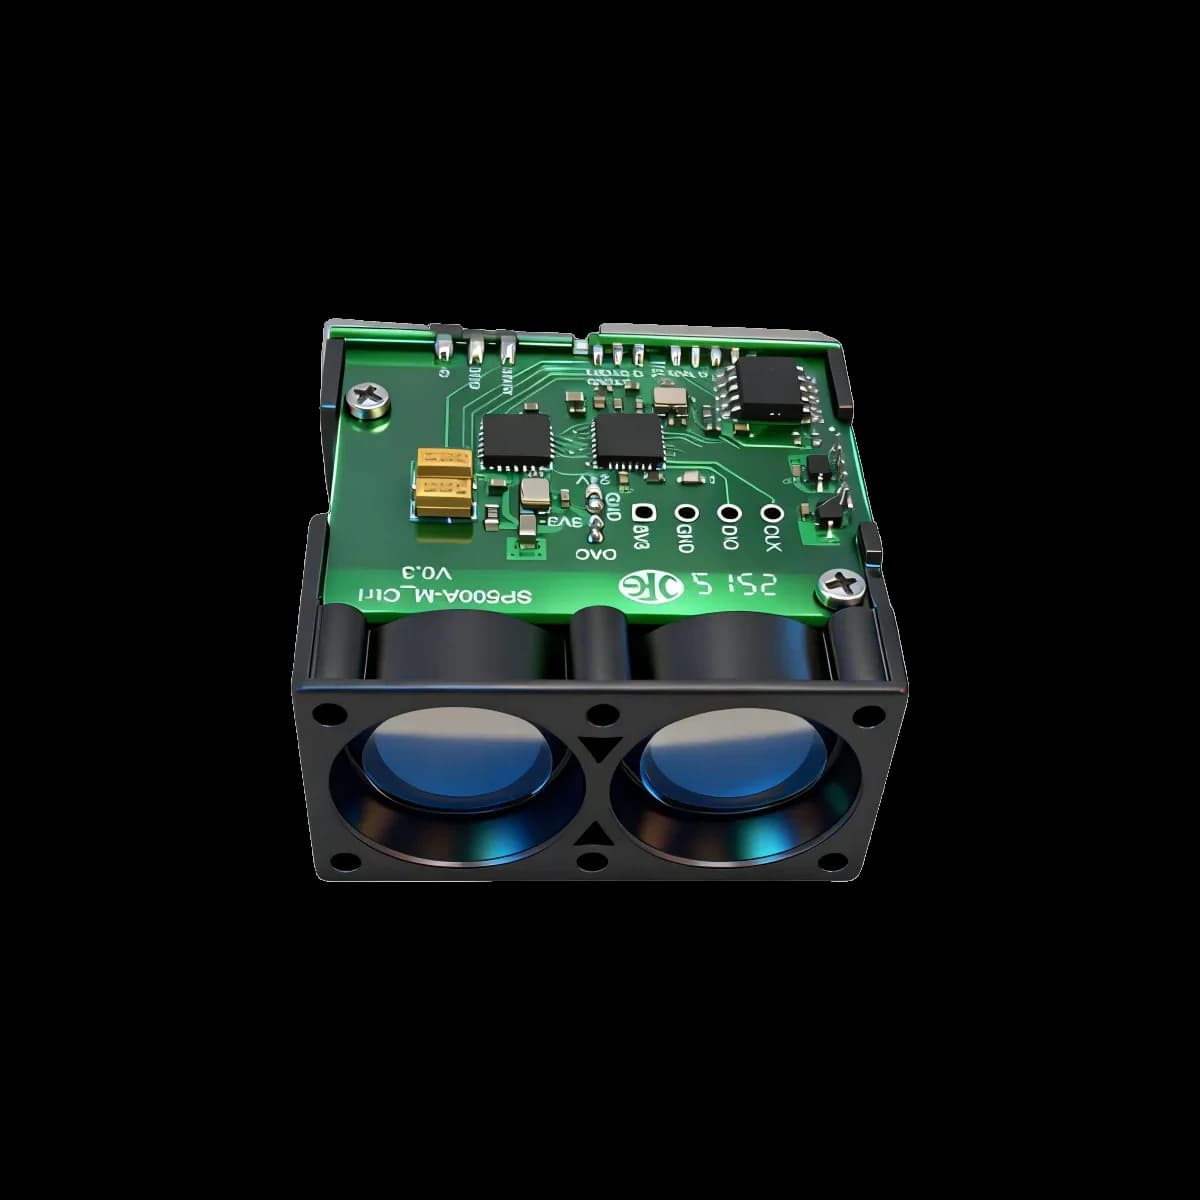
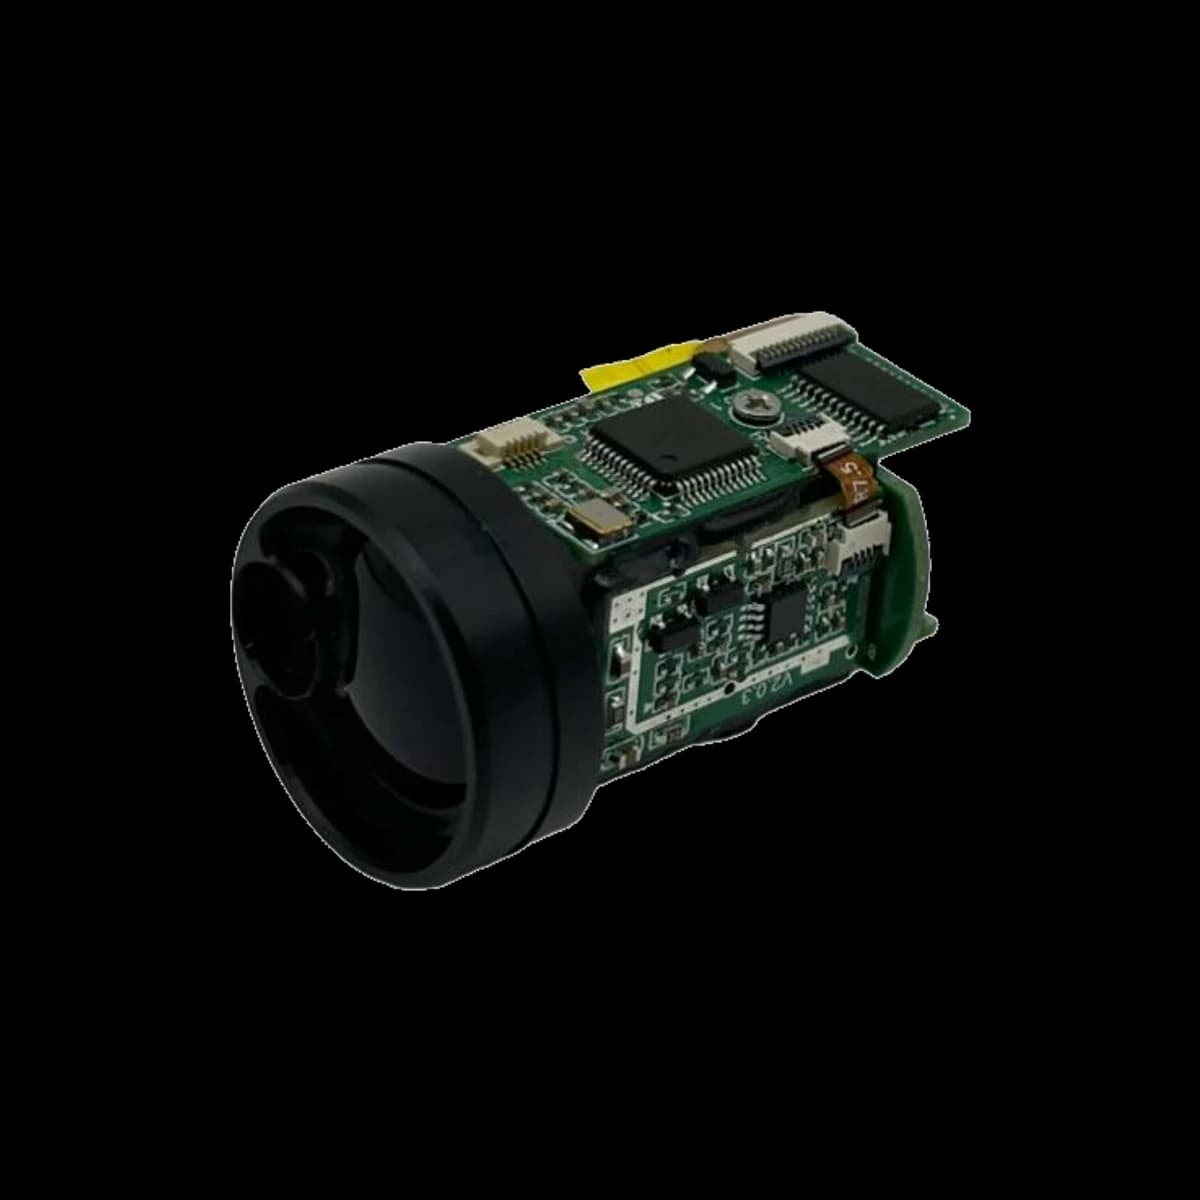
Meet the LR1500E2
The nominal 25.7 × 13.3 × 24.6 mm dimensions, mass no greater than 10 g and UART-TTL interface provide concrete host-selection details. This model can be evaluated for civilian handheld optics with distance readout. Its standard range does not establish equal reach on every low-reflectivity or small target.
The accuracy record starts at 6 m and changes formula at 500 m, with 90%-reflectivity whiteboards of specified sizes. Those conditions distinguish it from LR1500E4, whose source uses different accuracy intervals. The standard adaptive output rate should also remain separate from references to customized higher-rate versions.
1500 m range class
4–1500 m standard range with a model-specific long-distance accuracy formula.
Host-controlled ranging
2–10 Hz (adaptive); single-shot and continuous measurement modes.
Compact integration
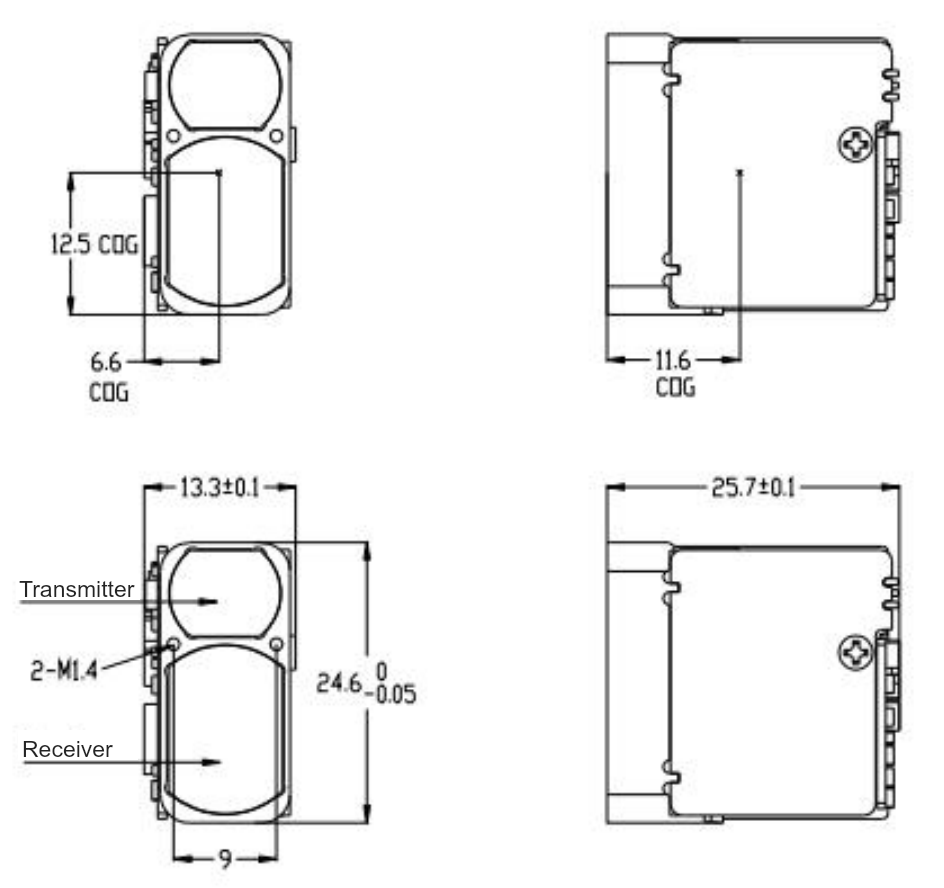
25.7 × 13.3 × 24.6 mm nominal dimensions in the current mechanical drawing; detailed tolerances remain controlling.
UART-TTL interface
115200 bps communication and a 3.3–5 V supply range; use the model-specific pinout and command table.
LR1500E2 Specifications
Read performance values with their target and test conditions. The linked user manual provides the complete mechanical, electrical, and communication details.
| Parameter | Value | Conditions / notes |
|---|---|---|
| Laser wavelength | 905 ± 5 nm | — |
| Measurement range | 4–1500 m | Standard range; actual reach depends on target and environment. |
| Ranging accuracy | ±1 m (6 m ≤ D < 500 m); ±(0.5 + 0.001D) m (500 m ≤ D ≤ 1500 m) | Whiteboard target, 90% reflectivity: 2.3 × 2.3 m for the first distance interval; 2.3 × 4.6 m for the second. |
| Measurement update rate | 2–10 Hz (adaptive) | Completed distance outputs; not the optical pulse-repetition rate. |
| Communication interface | UART-TTL | Custom configurations are specified separately. |
| Baud rate | 115200 bps | — |
| Supply voltage | 3.3–5 V | — |
| Operating temperature | −20 °C to +55 °C | — |
| Storage temperature | −40 °C to +60 °C | — |
| Mechanical drawing dimensions | 25.7 × 13.3 × 24.6 mm | Drawing nominal values. Observe the individual tolerances in the model drawing; do not machine from the rounded summary alone. |
| Weight | ≤10 g | — |
| Ingress protection | IP67 | Lens cavity only; not a blanket rating for the exposed board or the complete host product. |
| Laser safety class | Class 1 | As stated in the model manual; finished-equipment assessment is separate. |
| Laser beam divergence | < 6 mrad (small laser spot) | — |
| Optical material | Resin aspheric lens | — |
| Receiver aperture | 9.2 mm × 14.5 mm | — |
| Startup time | ≤ 200 ms | — |
| Inrush current | ≈ 350 mA | Approximate value in the specification table. |
| Sleep power consumption | < 1 mW | — |
| Standby power consumption | ≈ 0.2 W | Approximate value in the specification table. |
| Short-range power consumption | ≈ 0.4 W | Approximate value in the specification table. |
| Operating power consumption | ≈ 1 W | Approximate value in the specification table. |
- For civilian equipment only. The model manual prohibits military applications.
Operation and Data Output
Single-shot mode requests one reported distance. For a weak return, the manual describes repeated internal measurements before reporting stable distance data. Continuous mode produces repeated results at the documented adaptive update rate.
The standard measurement-rate specification is 2–10 Hz (adaptive). Higher-rate custom versions mentioned in the manual are separate configurations, not the default performance of a standard unit.
Electrical Interface
| Pin | Signal | Function |
|---|---|---|
| 1 | GND | Power ground |
| 2 | VCC | Power input |
| 3 | I/O (Reserved) | Reserved for expansion |
| 4 | TXD | Transmit data: module → host |
| 5 | RXD | Receive data: host → module |
| 6 | SW-SHOT | Function-enable input. The required control polarity must match the supplied configuration. |
Mechanical Dimensions
Use the drawing and its tolerances for installation. This drawing is reproduced directly from the current LR1500E2 user manual.
905 nm Pulsed Time of Flight and APD Reception
The following explains the general measurement principle of a 905 nm pulsed ranging system with APD reception. A short near-infrared pulse travels to the target, and reflected light returns through the receiving optics to a silicon avalanche photodiode (APD). The receiver converts the optical return into an electrical signal for distance measurement. Individual circuit implementations and performance remain model-specific.
Transmit pulse → target → reflected light
Receiving optics → APD → timing processing → host
A 1 m change in distance corresponds to about 6.67 ns of round-trip travel time in free space. This is a physical relationship, not a claim about the module’s timing resolution or measurement accuracy. [1]
Why an APD helps detect a weak return
A silicon APD provides internal avalanche gain before subsequent signal processing. This can help a receiver detect weak optical pulses, but the gain also brings excess noise. More gain is not always better: receiver bandwidth, background light, bias stability, and temperature all affect the usable signal-to-noise ratio. [2] [3] [8]
Why range depends on the target
A large, bright surface usually returns more usable light than a small, dark, or angled one. At long distances, beam spreading can place only part of the transmitted light on the intended target. The receiver also sees losses through the atmosphere and any protective window, so a maximum range rating must be read with its target conditions. [1] [4] [7]
Why wavelength stability and filtering work together
Narrowband optical filtering reduces unwanted background light while passing the laser return. Lower transmitter wavelength drift helps preserve this overlap as temperature changes. Filter bandwidth, incidence angle, component variation, and temperature must still be considered together; a narrow filter alone does not establish sunlight immunity. [5] [6] [7]
Why timing errors become distance errors
Noise changes the estimated arrival time of a return pulse. A fixed-threshold detector can also trigger at different times as pulse amplitude changes, an effect called timing walk. The complete receiver and timing chain determines the final measurement error—not the detector response time by itself. [1] [8] [12]
Choose by Target, Range, and Integration
The E2 and E4 families cover 1000, 1200, 1500, and 2000 m nominal range classes. LRF1200A1 and LRF3000A1 have their own electrical, mechanical, and measurement specifications. Equal range-class numbers do not make different families pin-compatible or mechanically interchangeable.
Start with the smallest and darkest target your application must measure, the required update rate, and the available installation space. Then compare the model-specific supply, interface, drawing, and long-range accuracy formula. Do not select only by the maximum range number.
Integration Applications
- Handheld observation and ranging instruments
- Night-vision and thermal-imaging equipment with distance readout
- Telescopes and outdoor ranging instruments
Validate the complete installation with representative targets, lighting, temperature, and the final protective window.
From Bench Test to Installed System
- Power and signals: size the supply for transient current, use a common signal ground, and match logic levels. A module’s supply-voltage range is not automatically the voltage tolerance of its UART pins.
- Optical window: choose material and coatings with suitable transmission near 905 nm. Keep transmit-to-receive reflections low, avoid aperture clipping, and test the assembled window for false near returns.
- Target: test dark, small, angled, wet, and partially obscured surfaces at the required distance rather than only a large white panel.
- Environment: assess direct sunlight, visibility, condensation, dust, and temperature changes. Keep the optical surfaces clean.
- Data handling: use the model manual for byte order, scaling, checksum, and command timing. Check the STA/status field before interpreting the distance bytes, and reject failed measurements according to the model protocol.
- Laser safety: assess the finished equipment, including added optics, controls, access, labeling, and applicable operating conditions. A component rating alone does not establish the system’s laser class.
LR1500E2: Frequently Asked Questions
What is the documented near limit for LR1500E2 accuracy?
The standard range begins at 4 m, but the accuracy table’s first interval starts at 6 m. The source does not supply an accuracy value for every point in that near-range gap. Use the stated intervals or obtain a confirmed model-specific value.
Why does the page retain the 500 m accuracy breakpoint?
LR1500E2 specifies ±1 m below 500 m and ±(0.5 + 0.001D) m from 500 m to 1500 m, with D in meters. Replacing those intervals with another model’s 400 m breakpoint would alter the controlled performance statement.
What target conditions support the accuracy figures?
The source gives 90%-reflectivity whiteboards: 2.3 × 2.3 m for the first interval and 2.3 × 4.6 m for the second. These are not generic small-target claims. Retain them when comparing the module with a real outdoor observation task.
How is the compact E2 package characterized?
The nominal drawing dimensions are 25.7 × 13.3 × 24.6 mm and the stated mass is no greater than 10 g. Use the complete mechanical record for tolerances and mounting. Neither low mass nor the E2 name proves interchangeability with E4.
Is a higher customized frequency part of the standard module?
The standard source gives 2–10 Hz adaptive measurement output. A higher-rate customized version is a separate configuration and should not be assumed in a normal order. Confirm the required setting and target behavior before accepting an instrument-level update requirement.
Product Documentation and Technical Literature
The model manual defines product specifications. The references below explain measurement principles and integration effects; results from other systems are not LR1500E2 performance ratings.
- LR1500E2 User Manual — v1.2 · 2025.10 · Public edition 2026-09-06Current model specifications, drawings, and communication protocol.
- [model-reading-2] Performance Analysis of Next-Generation LADAR for Manufacturing, Construction, and MobilityGeneral background on laser ranging and target/environmental influences; not validation of this ERDI model.
- [1] Pulsed time-of-flight laser range finder techniques for fast, high precision measurement applicationsAri Kilpelä. University of Oulu, 2004-01-30. Direct pulsed-ToF principle, d = c_airΔt/2, timing precision, pulse slew rate, receiver noise and timing walk. Scope: Short-range research prototypes and their numerical results are not ERDI product specifications.
- [2] Influence of Temperature Variation on Optical Receiver Sensitivity and its CompensationAleš Prokeš. Radioengineering; Brno University of Technology institutional repository, 2007-09. Temperature dependence of silicon-APD gain, excess-noise factor, dark current and receiver sensitivity; reverse-bias temperature compensation. Scope: The calculations use a specific APD/TIA free-space optical receiver; no numerical curve is transferable to an ERDI module.
- [3] Multiplication Noise in Uniform Avalanche DiodesR. J. McIntyre. IEEE Transactions on Electron Devices, 1966-01. Avalanche multiplication is not noiseless; multiplication noise depends on gain and carrier ionization statistics. Scope: Ideal uniform-multiplication and white-noise theory; real devices and complete receivers require further modeling and measurement.
- [4] Analysis of the Backscattered Energy in Terrestrial Laser Scanning DataNorbert Pfeifer; Bernhard Höfle; Christian Briese; Martin Rutzinger; Alexander Haring. ISPRS, 2008. Lidar link equation; target reflectance, effective area, incidence angle, beam divergence, range, aperture and atmospheric/system transmission. Scope: The experiments use terrestrial scanners around 1540–1550 nm. The general link-budget relationships are relevant here; the measured values are not ERDI specifications.
- [5] Fabry–Perot interferometer as a solar background noise suppressor: application to daytime lidarKarnam Raghunath; Karnam Ramesh; Sanama Narayana Reddy. Annals of Geophysics, 2012-06-05. Daylight solar background degrades lidar SNR; receiver field of view and narrow spectral filtering are relevant mitigations. Scope: The study concerns atmospheric lidar rather than a compact 905 nm module. Its reported SNR improvement is specific to the experimental system.
- [6] Wavelength-Stabilized High-Pulse-Power Laser Diodes for Automotive LiDARAndrea Knigge; Andreas Klehr; Hans Wenzel; Anissa Zeghuzi; Jörg Fricke; Andre Maaßdorf; Armin Liero; Günther Tränkle. physica status solidi (a), 2018-01-16. A 905 nm pulsed laser source can exhibit temperature-dependent wavelength shift; wavelength stabilization is relevant over a wide temperature span. Scope: The Bragg-grating device and 65 pm/K result are research-specific and do not describe an ERDI emitter.
- [7] LiDAR Evaluation System: Measurement of Transmittance of Bandpass FiltersRisa Fuji; Kazumi Kawahara. Shimadzu Corporation, 2020-03-26. Protective-window and bandpass-filter transmission should be evaluated near 905 nm across incidence angle; passband and throughput can change with angle. Scope: This measurement application note explains optical characterization methods. It is not an ERDI performance test or a statement of component sourcing.
- [8] Wide dynamic range CMOS receiver techniques for a pulsed Time-of-Flight laser rangefinderAram Baharmast. University of Oulu, 2021-08-27. Receiver noise and bandwidth, input-pulse amplitude and width, SNR, timing walk, jitter and dynamic range are system-level coupled quantities. Scope: The CMOS implementation and prototype figures are research-specific and do not imply ERDI uses the same architecture.
- [9] Comparison of 905 nm and 1550 nm semiconductor laser rangefinders' performance deterioration due to adverse environmental conditionsJacek Wojtanowski; Marek Zygmunt; Mirosława Kaszczuk; Zygmunt Mierczyk; Michał Muzal. Opto-Electronics Review, 2014-06-29. Range depends on visibility-related atmospheric attenuation and target-reflectance changes caused by surface condition, with wavelength-dependent effects. Scope: Modeled selected conditions; it does not prove a universal 905 nm versus 1550 nm ranking or any ERDI range.
- [10] JCGM 200:2012 — International Vocabulary of Metrology: Basic and General Concepts and Associated Terms (VIM), 3rd editionJoint Committee for Guides in Metrology. BIPM/JCGM, 2012. Authoritative distinctions among measurement accuracy, precision/repeatability and resolution. Scope: Defines metrology terms; it does not provide a laser-rangefinder test method or product value.
- [11] IEC 60825-1:2014 — Safety of laser products – Part 1: Equipment classification and requirementsInternational Electrotechnical Commission. IEC, 2014-05-15. Laser classification applies to the laser product and its accessible emission; a component designation does not automatically establish the finished-equipment classification. Scope: The public page is a summary, not the full standard, test report or compliance certificate.
- [12] Methods of Precise Distance Measurements for Laser Rangefinders with Digital Acquisition of SignalsMichał Muzal; Marek Zygmunt; Piotr Knysak; Tadeusz Drozd; Marcin Jakubaszek. Sensors, 2021-09-26. 905 nm direct-ToF equation, waveform timing extraction, bias versus random error, uncertainty, and use of multiple pulses in a measurement method. Scope: The one-centimeter laboratory result is specific to the research prototype and measurement method, not an ERDI product specification.